Getting Started with FRDM-A-S32M276 Development Board Setup and Programming
Contents of this document
-
Introduction
-
Out of Box
-
Get Software
-
Plug It In
Sign in to save your progress. Don't have an account? Create one.
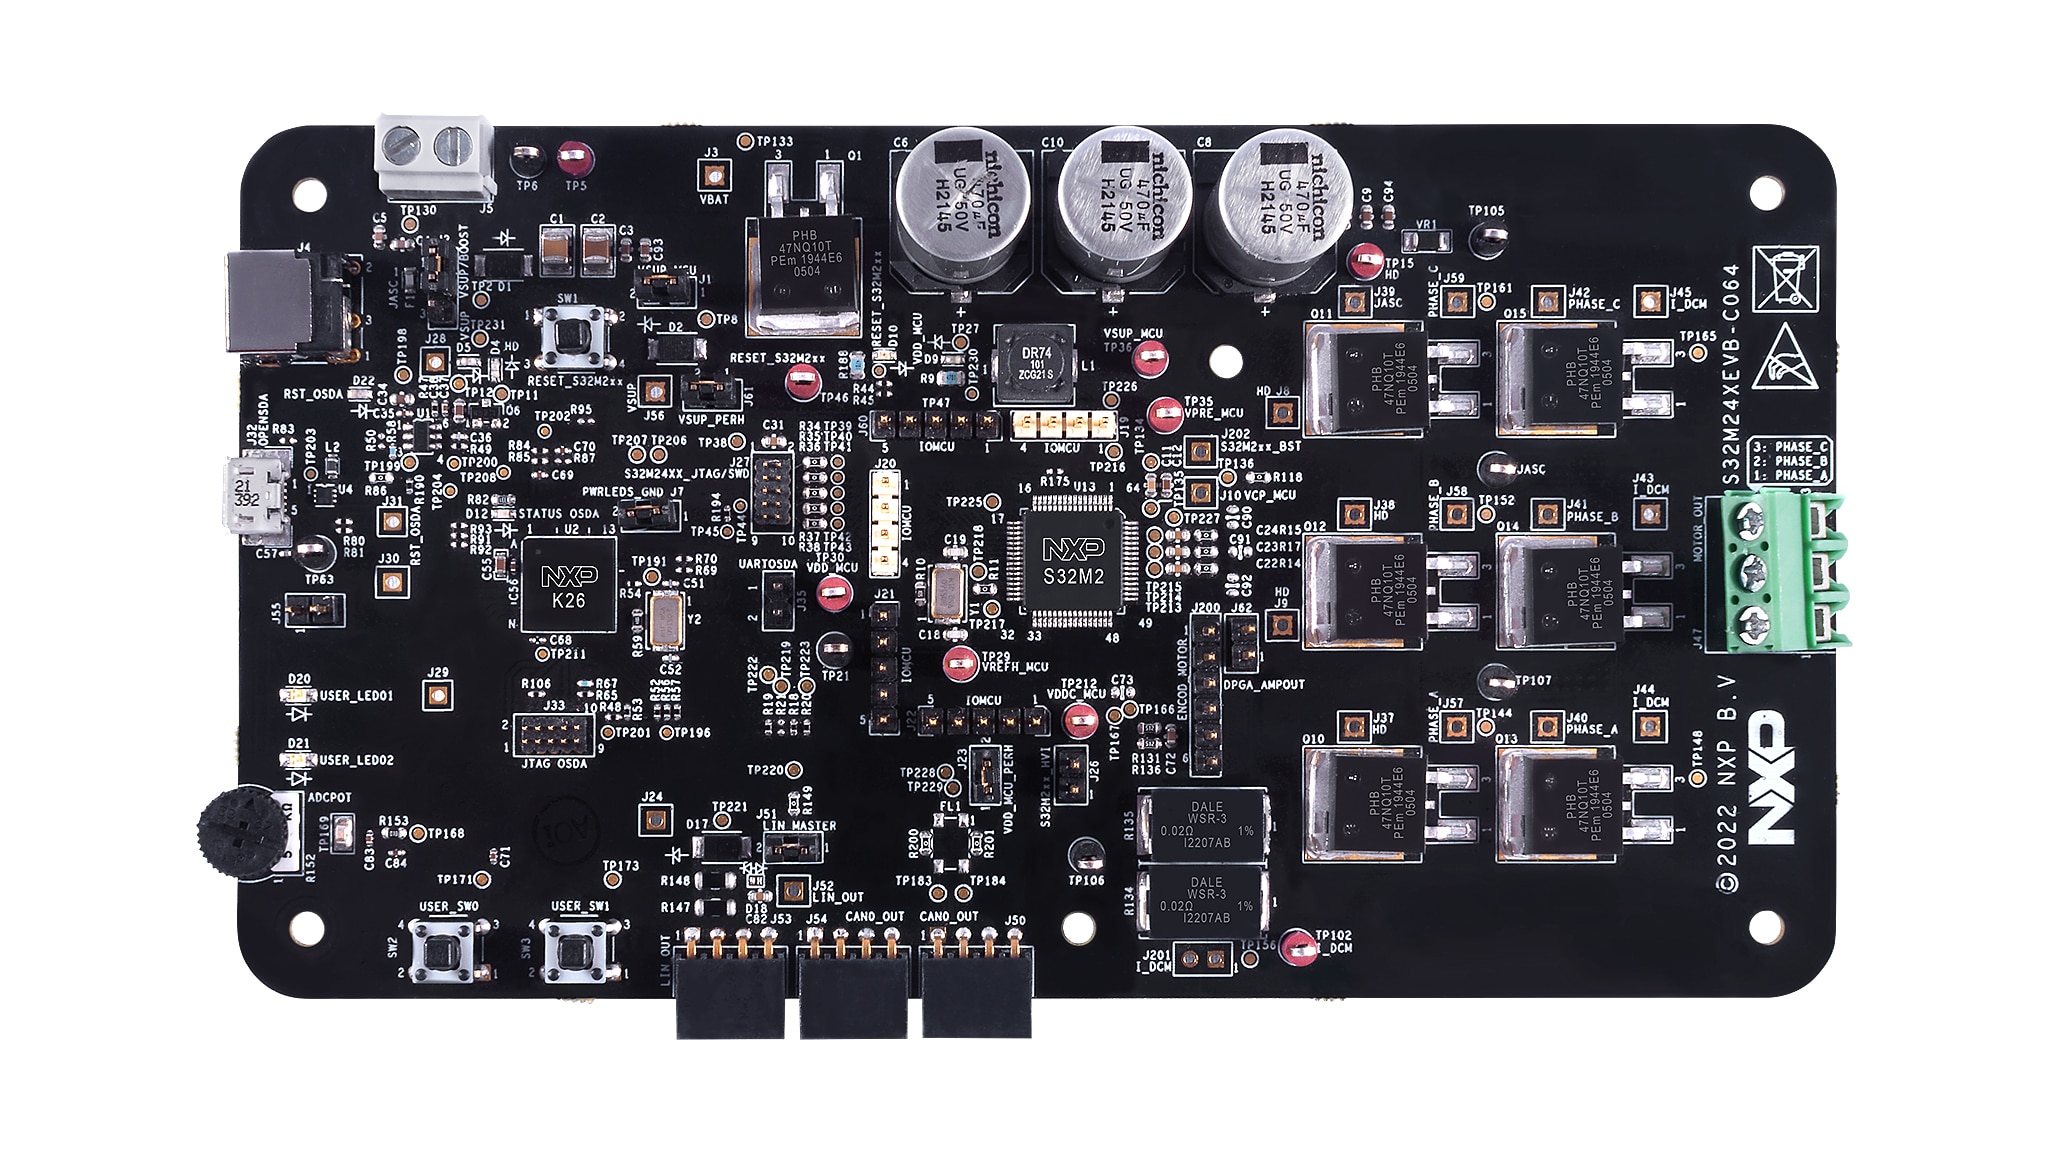
Purchase your FRDM Automotive S32M276 Development Board
1. Introduction
1.1 Introduction
This Getting Started template describes the first steps and SW installation setup for S32M27XEVB-SW version 2.x.
The Getting Started for older S32M27XEVB-SW package version 1.x is distributed inside S32M27XEVB-SW.exe package in pdf format.
2. Out of Box
2.1 Get to Know the FRDM-A-S32M276 Development Board

2.2 Get to Know the FRDM-A-S32M276 Features

3. Get Software
Sign in at NXP.com with your credentials.
3.1 Select SW Packages from Automotive Software Package Manager
Open Automotive Software Package Manager and select S32K3 device - contains software also compatible with S32M27x.

Unfold the FRDM Automotive Board Installation Package bundle and check S32 Design Studio, Real-Time Drivers and FreeMASTER software. Other SW packages are optional.

Click on Generate Bundle Installer button at end of the page.

Follow the wizard instructions for Export Control and SW License Agreement (need to scroll whole text down before accepting). After that, you may close wizard window. Installer and Installer User Manual download will start automatically in a few moments.

The FRDM Automotive Board Installation Package bundle allows to enable automatic installation and configuration sw without any interaction. That simplifies the installation procedure.

3.2 Add GCC Toolchain Version 10.2
Latest versions of the S32 Design Studio contain GCC toolchain only in version 11.4. For full compatibility with RTD, you need to install GCC also in version 10.2.
In S32 Design Studio, go to Help → S32DS Extensions and Updates from the top menu to open the S32DS Extensions and Updates dialogue where you may install it.

3.3 Add FreeMASTER Communication Driver for S32M27x
Download updatesite file with FreeMASTER Communication Driver for S32M2.


In S32 Design Studio, go to Help → S32DS Extensions and Updates from the top menu to open the S32DS Extensions and Updates dialogue where you click on Add Update Sites and install it.


3.4 Get FreeMASTER Application Tool for Real-Time Debugging
Download and install FreeMASTER application tool for real-time debugging.

3.5 Get Automotive Math and Motor Control Library (AMMCLib) Set
Download and install AMMCLib for S32M27x.


3.6 Download the Development Kit Application Software
Download and install FRDM-A-S32M276 motor control application software package.


4. Plug It In
The recommended accessory kit for FRDM-A-S32M276 board is NXP BLDC_KIT (sw developed and tuned for given motor), however you may use any suitable 3 ph motor and 12 V power supply instead.

BLDC_KIT Content:
- 95 W BLDC motor with HALL sensors Sunrise 42BLY3A78-24110
- Plexiglass
- 12 V, 5 A power supply Meanwell GST60A12-P1J
- power supply cable with set of universal plugs
- Four self-adhesive standoffs for any EVB Takachi AST3-10B
- micro-USB cable
4.1 Check the Default Jumper Positions at the FRDM-A-S32M276 Evaluation Board

Table 1. FRDM-A-S32M276 Default Jumper Settings
| Jumper | State | Notes |
|---|---|---|
J1 |
CLOSED | VSUP_MCU is routed to VSUP input of MCU |
J2 |
1-2 | VBAT is routed to VSUP. Boost Converter disconnected |
J7 |
CLOSED | Power domains LED Indicators enabled |
J23 |
CLOSED | VDD_MCU is connected to the VDD_MCU_PERH |
J26 |
OPEN | [1] High Voltage Input, [2] GND |
J35 |
OPEN | [1] LPUART0_RX, [2] LPUART0_TX |
J51 |
CLOSED | LIN Commander* mode |
J55 |
OPEN | ADC Potentiometer disabled |
J61 |
CLOSED | VSUP is routed to VSUP_PERH |
J201 |
OPEN | Current shunt voltage, not populated |
4.2 Plug the Motor

4.3 Optionally Plug the Encoder/HALL Sensors (Only for Sensor-Based SW Application

4.4 Plug the Power Supply and USB Debug Interface

4.5 Optionally to Previous Step Plug the JTAG Debug Interface and UART Interface

Build Application Project
Let's take your FRDM-A-S32M276 motor control evaluation board for a test drive.
Select Application and MCU Programing
Select the appropriate PMSM or BLDC motor control application from the installed directory NXP\MC_DevKits\S32M27xEVB\sw
To import the installed application software project in the S32 Design Studio IDE for S32 Platform:
- Launch S32DS for S32 Platform
- Go to File > Import, then select General > Existing Projects into Workspace
- Navigate to the installed application directory:
NXP\MC_DevKits\S32M27xEVB\swand choose appropriate project and click OK. Then, click Finish


Use Configuration Tool
- Unfold structure of the project with low-level drivers and double-click on
*.mexfile to open the project configuration in Configuration Tool - Please ensure that you configure appropriate project and click on "Update Code" button for generating configuration files


Upload Software and Debug
- In S32DS, return back to the C/C++ perspective
- Use the Debug Configuration menu and select the predefined debug configuration for building and uploading software into MCU
- The S32DS will switch into debug perspective where you may let the code run by clicking on Resume (or press F8), and use Disconnect to avoid interference between the S32DS IDE debugger and the FreeMASTER tool


Set Up the Debugging Tool
Launch the FreeMASTER application.
To open the *.pmpx FreeMASTER project <selected project>\FreeMASTER_control, click File > Open Project.

To enable communication, in the FreeMASTER tool bar, click Go (or press Ctrl+G).

Successful communication displays in the status bar at the bottom as:
RS-232; port=COMn; speed = 115200
Application Control
Application Setup (Optional Step)
If you run FRDM-A-S32M276 sw on modified or own hardware platform, you may need to edit hardware scales and fault triggers. In the Motor Control Application Tuning (MCAT) Tool switch to Application Setup page and edit values on left side.

Once you finish, click on Save config to generate static configuration file. You may check file content at Output file page.
Now, repeat step from Upload Software and Debug section to build the project and upload the code into MCU.
Motor Parametrization and Control Loops Autotuning (Optional Step)
In a case of motor change, you may benefit from new MCAT 2.0 motor parametrization and control loops autotuning features.
At Motor Parameters page, fill four basic motor parameters that cannot be detected automatically:
- Number of pole pairs
- Nominal Current
- Nominal Speed
- Maximum Speed
Click on Update target button and start the motor parameters estimation and automating tuning for control loops. Parameters are automatically updated typically in less than a minute.

For more information about the automatic motor parametrization and control loops autotuning please read AN15061 Application Note in S32M27xEVB\doc folder. Default path: c:\NXP\MC_DevKits\S32M27XEVB\doc\ApplicationNotes\AN15061 MCAT 2.0 - Motor Control Application Tuning Tool for PMSM FOC.pdf
Spin the Motor
Switch for example to Speed Loop page. Under Speed control tab, configure Required speed and turn on the motor drive.

Select one of predefined Scopes or Recorders in Project Tree to watch the application variables real-time.
For comfortable run-time debugging you may create or modify any of scopes or recorders.

- Check pending faults
In case of pending faults (fault state - fast blinking USER_LED01), click the CLEAR button at MCAT control tab or alternatively press simultaneously SW2 and SW3 on the board.

- Start application
Click On/Off on the control bar or press SW2/SW3 on the board to initiate clockwise/counterclockwise spinning of the rotor. Run state is signalized by slowly blinking USER_LED01.
- Set Speed
Modify Required speed field on the Speed control bar or change Speed Required in Variable Watch window. Alternatively control speed by pressing SW2 or SW3 switches on the board.

- Stop Application
Stop the motor by clicking On/Off button on the MCAT control page, clear On/Off variable or simultaneously press and hold SW2 and SW3 on the FRDM-A-S32M276 board. Ready state is signalized by steadily light at both USER_LED01 and USER_LED02.
RTD Examples
Kickstart your RTD journey with these handy examples. We've rounded up some of the most common use cases to get you inspired and moving forward.
Users can copy the path directly into their window once the RTD is downloaded.
RTD Examples
AE HANDLER FAULTS
C:\NXP\S32DS.3.6.1\S32DS\software\PlatformSDK_S32K3\RTD\Ae_TS_T40D34M30I0R0\examples\S32DS\S32M276\Ae_Handler_Faults_Example_DS_001_S32M276AE SPI
C:\NXP\S32DS.3.6.1\S32DS\software\PlatformSDK_S32K3\RTD\Ae_TS_T40D34M30I0R0\examples\S32DS\S32M276\Ae_Spi_Example_DS_001_S32M276AEC SPI
C:\NXP\S32DS.3.6.1\S32DS\software\PlatformSDK_S32K3\RTD\Ae_TS_T40D34M30I0R0\examples\S32DS\S32M276\Aec_Ip_Spi_Example_DS_001_S32M276CAN TRCV
C:\NXP\S32DS.3.6.1\S32DS\software\PlatformSDK_S32K3\RTD\CanTrcv_43_AE_TS_T40D34M30I0R0\examples\S32DS\S32M276\CanTrcv_Example_S32M276DPGA
C:\NXP\S32DS.3.6.1\S32DS\software\PlatformSDK_S32K3\RTD\Dpga_TS_T40D34M30I0R0\examples\S32DS\S32M276\Dpga_example_S32M276DPGA IP
C:\NXP\S32DS.3.6.1\S32DS\software\PlatformSDK_S32K3\RTD\Dpga_TS_T40D34M30I0R0\examples\S32DS\S32M276\Dpga_Ip_example_S32M276GDU
C:\NXP\S32DS.3.6.1\S32DS\software\PlatformSDK_S32K3\RTD\Gdu_TS_T40D34M30I0R0\examples\S32DS\S32M276\Gdu_Example_DS_S32M276LIN TRCV
C:\NXP\S32DS.3.6.1\S32DS\software\PlatformSDK_S32K3\RTD\Lin_43_LPUART_FLEXIO_TS_T40D34M30I0R0\examples\S32DS\S32M276\Lin_LinTrcv_Flexio_MasterFrameTransfer_S32M276LIN TRCV LPUART
C:\NXP\S32DS.3.6.1\S32DS\software\PlatformSDK_S32K3\RTD\Lin_43_LPUART_FLEXIO_TS_T40D34M30I0R0\examples\S32DS\S32M276\Lin_LinTrcv_Lpuart_MasterFrameTransfer_S32M276CLOCK IP
C:\NXP\S32DS.3.6.1\S32DS\software\PlatformSDK_S32K3\RTD\Mcu_TS_T40D34M30I0R0\examples\S32DS\S32M276\Clock_Ip_Example_S32M276MCU
C:\NXP\S32DS.3.6.1\S32DS\software\PlatformSDK_S32K3\RTD\Mcu_TS_T40D34M30I0R0\examples\S32DS\S32M276\Mcu_Example_S32M276POWER IP
C:\NXP\S32DS.3.6.1\S32DS\software\PlatformSDK_S32K3\RTD\Mcu_TS_T40D34M30I0R0\examples\S32DS\S32M276\Power_Ip_Example_S32M276MEM OTP IP
C:\NXP\S32DS.3.6.1\S32DS\software\PlatformSDK_S32K3\RTD\Ocotp_TS_T40D34M30I0R0\examples\S32DS\S32M276\Mem_Otp_Ip_Example_S32M276OCOTP
C:\NXP\S32DS.3.6.1\S32DS\software\PlatformSDK_S32K3\RTD\Ocotp_TS_T40D34M30I0R0\examples\S32DS\S32M276\Ocotp_Example_S32M276PLATFORM MPU HLD
C:\NXP\S32DS.3.6.1\S32DS\software\PlatformSDK_S32K3\RTD\Platform_TS_T40D34M30I0R0\examples\S32DS\S32M276\Platform_MPU_HLD_Example_S32M276MPU IP
C:\NXP\S32DS.3.6.1\S32DS\software\PlatformSDK_S32K3\RTD\Platform_TS_T40D34M30I0R0\examples\S32DS\S32M276\Platform_MPU_IP_Example_S32M276PORT
C:\NXP\S32DS.3.6.1\S32DS\software\PlatformSDK_S32K3\RTD\Port_TS_T40D34M30I0R0\examples\S32DS\S32M276\Port_Example_S32M276SIUL2 PORT IP
C:\NXP\S32DS.3.6.1\S32DS\software\PlatformSDK_S32K3\RTD\Port_TS_T40D34M30I0R0\examples\S32DS\S32M276\Siul2_Port_Ip_Example_S32M276WDOG
C:\NXP\S32DS.3.6.1\S32DS\software\PlatformSDK_S32K3\RTD\Wdg_TS_T40D34M30I0R0\examples\S32DS\S32M276\Wdg_Example_S32M276WDOG IP
C:\NXP\S32DS.3.6.1\S32DS\software\PlatformSDK_S32K3\RTD\Wdg_TS_T40D34M30I0R0\examples\S32DS\S32M276\Wdg_Ip_Example_S32M276Design Resources
Board Information
Chip Documents
Support
Forums
Connect with other engineers and get expert advice on designing with the FRDM-A-S32M276 Reference Design Board using our community sites.
On this page
- 3.1
Select SW Packages from Automotive Software Package Manager
- 3.2
Add GCC Toolchain Version 10.2
- 3.3
Add FreeMASTER Communication Driver for S32M27x
- 3.4
Get FreeMASTER Application Tool for Real-Time Debugging
- 3.5
Get Automotive Math and Motor Control Library (AMMCLib) Set
- 3.6
Download the Development Kit Application Software
- 4.1
Check the Default Jumper Positions at the FRDM-A-S32M276 Evaluation Board
- 4.2
Plug the Motor
- 4.3
Optionally Plug the Encoder/HALL Sensors (Only for Sensor-Based SW Application
- 4.4
Plug the Power Supply and USB Debug Interface
- 4.5
Optionally to Previous Step Plug the JTAG Debug Interface and UART Interface
- Select Application and MCU Programing
- Use Configuration Tool
- Upload Software and Debug
- Set Up the Debugging Tool